enabling centralized monitoring, control, and navigation of diverse robotic systems through a single platform
-
Holonomic optimized navigation
Enables precise and flexible maneuvering by optimizing Nav2 parameters in consideration of the robot’s travel path. -
Advanced localization and stability
Maintains stable positioning (localization) even on unstable floors or in feature-sparse corridors by fusing LiDAR scan data, IMU, and depth camera data. -
Intelligent Behavior Tree
Executes intelligent scenarios that trigger robot-specific actions and sub- functions upon reaching each way point.
- Position verification, safety factor assessment, and monitoring temperatures in surrounding and noise levels etc. -
Recognizing real-time AI vision
Performs real-time detection of obstacles, human identification, and anomaly detection during navigation using AI-based models, and immediately transmits the results to the control center. -
Autonomoux return and charging
After completing patrol tasks, or during patrol when battery level drops, the robot autonomously decides to return for charging, begins battery recharging, and automatically resumes its mission upon completion.
-
Holonomic Optimized
NavigationAchieve precise and flexible maneuverability through Nav2 parameter tuning that reflects the locomotion characteristics of quadruped robots.
-
Advanced Position Estimation (Localization)
Perfect location detection even in slippage or featureless halls by integrating LiDAR scans, IMU, and Depth Data together.
-
Error Recovery and Autonomous Stability
A fail-safe logic that immediately pauses and restarts operation in the event of system or localization errors is applied (proved 93% navigation success rate).
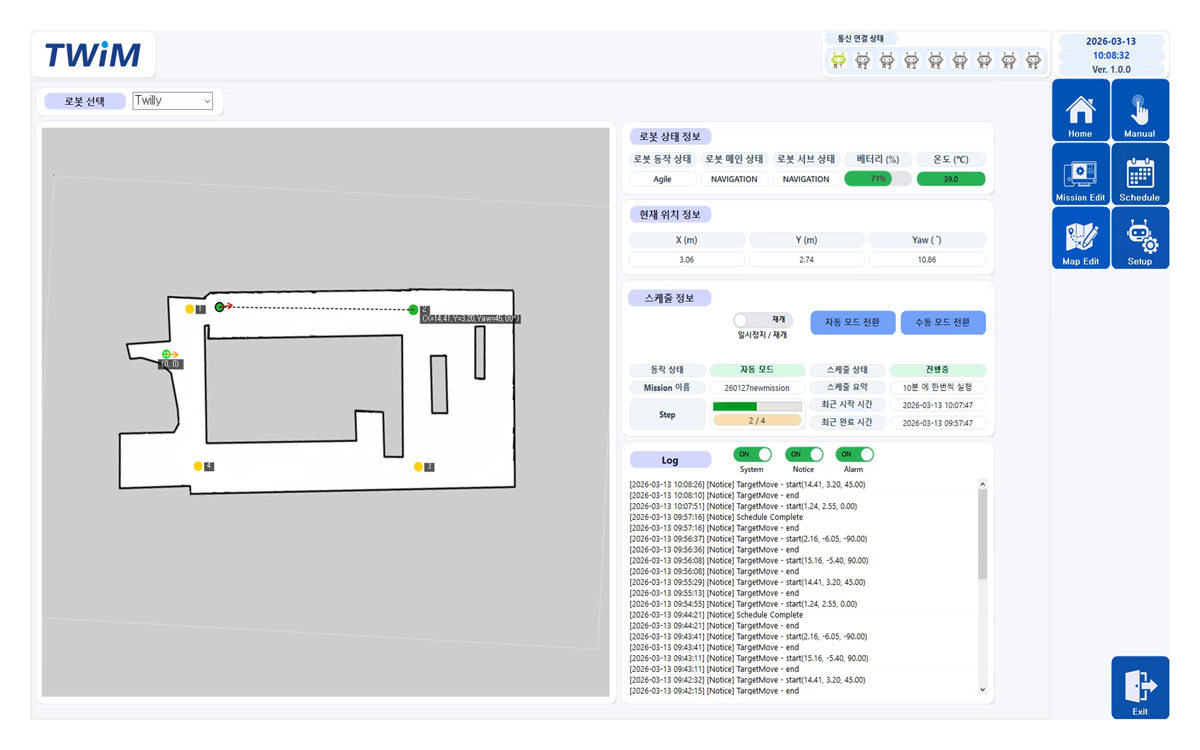
-
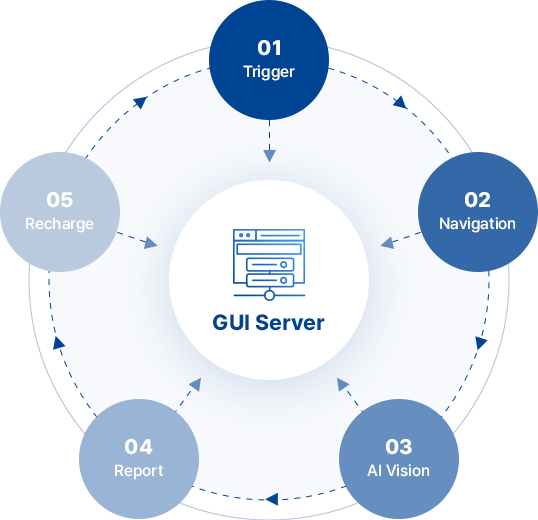
01. Start patrolling(Trigger)
Automatic path generation and start command from the GUI server.
-
02. Point navigation(Navigation)
Precise localization and obstacle avoidance based on Nav2.
-
03. Intelligent scanning(AI Vision)
360-degree rotation at waypoints, with worker detection and image capture using YOLOv8.
-
04. Control center reporting(Report)
Node-based results are accumulated and stored in JSON format, and immediately transmitted to the GUI upon patrol completion.
-
05. Autonomous return and charging(Recharge)
Automatically navigates to and docks at the charging station(success rate: 97%).
-
Quick application
Enables quick on-site implementation by completing spatial mapping in a single autonomous navigation run. -
Stable management
In the event of a system stop due to errors, it autmotically reutnrs to mission through the automatic recovery. -
Online monitoring
Robot operations and data collection can be freely monitored from the control center, and results can be reported.
-
Autonomous patrol for offices and buildings
Human detection and security inspections during nighttime or unoccupied hours -
Safety management for industrial sites
Complements blind spots of fixed cameras to ensure worker safety monitoring -
Smart farming (farm)
Pest detection and plant growth condition monitoring -
Special environment navigation
Detects gas leaks and abnormal temperatures by integrating additional sensors such as ultrasonic and IR sensors