G1
Leveraging TWIM's AI vision inspection and factory automation technologies, we plan to provide ready-to-deploy solutions for industrial sites.
-
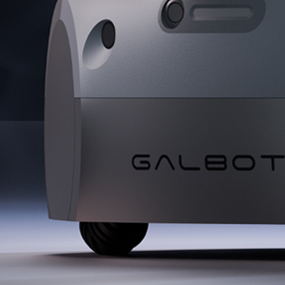 Chassis
A 360° omnidirectional-wheel chassis enables full-directional mobility and in-place rotation, delivering stable, quiet, and high-tempo movement on structured surfaces.
-
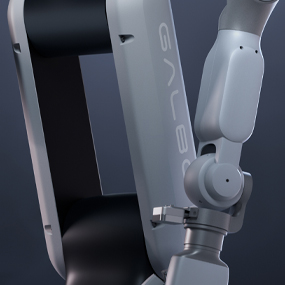 Operation
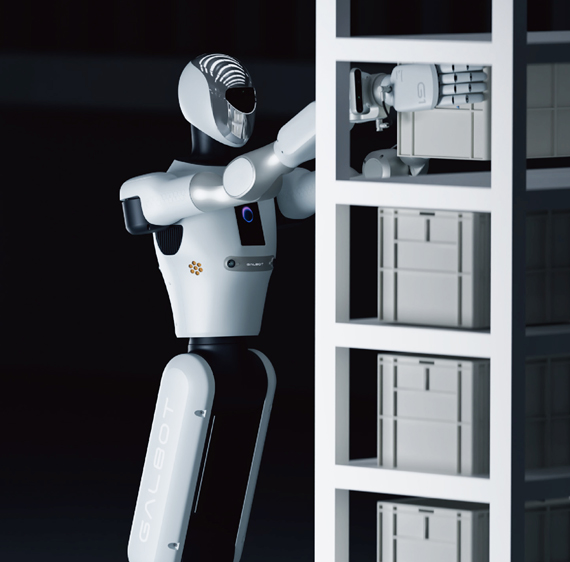
Through coordinated motion control between the leg-folding mechanism and the long-reach manipulator, the system achieves full height coverage from 0 to 2.4 m, stably adapting to tasks across different working heights.
-
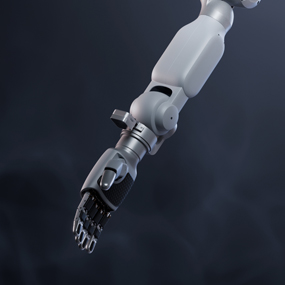 Mechanical Arm
Designed for real-world operational workflows, it delivers a horizontal reach of up to 1.9 m while handling payloads of up to 10 kg, enabling stable and predictable grasping and handoff.
-
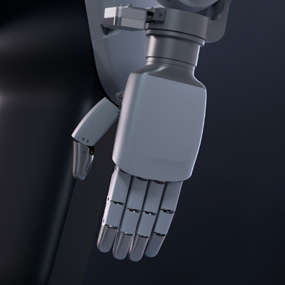 Dexterous Hand
The dexterous hand features a modular design with EVA-based impact protection, allowing seamless switching between mechanical grippers and pneumatic suction end-effectors to balance gripping stability and compliant grasping force.
By fusing visual and auditory (or 3D) perception, the system constructs a dynamic environmental model that supports intent understanding, voice interaction, and target recognition.
Action planning driven by scene understanding enables intelligent decision-making in real-world operational environments.
An automotive-grade dual architecture combining XCU and NPU ensures secure and real-time communication across the system.
-
Multimodal Perception
Autonomous return-to-charge with up to 8 hours of operating time.
-
Industrial Protection
Rated IP54 for industrial protection, the enclosure is resistant to liquid splashes from any direction.
-
Interactive
A 6.25-inch smart interactive display enables the robot to be readable, controllable, and collaborative on site.
-
Standard Posture Height
1730mm
-
Torso Lift Range
650mm
-
Chassis Dimensions (L×W)
600 X 600mm
-
Arm Length (Shoulder to Wrist)
710mm
-
Workspace (Wrist Center)
Vertical 0~2100mm
Horizontal 1900mm -
Body Weight
92.5kg
-
Battery Capacity
48V 30Ah
-
Charging Specifications
54.64V 10Ah
-
Full Charge Runtime
8h
-
Head
Binocular Camera x 1
-
Wrist
Depth Camera x 2
6-Axis Force Sensor x 2 -
Torso
RGB Camera x 4
IMU x 2 -
Chassis
3D LiDAR x 1
Ultrasonic Sensor x 8
IMU x 1
-
Speaker
5W x 2
-
Network
Wi-Fi 2.4 / 5GHz
Bluetooth 5.2 -
Display
5.5" Touchscreen
Resolution 1920 x 1080 -
Microphone
Linear 4-Mic Array x 2
-
Computing Platform
AGX Orin 64GB 275TOPS
-
Dual-Arm End Payload
Single Arm : 5kg
Total : 10kg -
Multiple End Effectors Supported
Parallel Gripper
Electric Suction Cup, etc. -
Driven Joints (Excl. End Effectors)
Legs 2 + Waist 2 + Neck 2 = 6
Dual Arms 7x2 = 14
Chassis Drive Wheels 4
Total 24
- Unmanned convenient store
- Robot café
- Unmanned pharmacy
- Worksites requiring repetitive transport of items weighing up to 10 kg, which may cause operator fatigue
- Loading/unloading relay operations between standalone equipment
- Product transportation in environments hazardous to workers
- Physical AI R&D